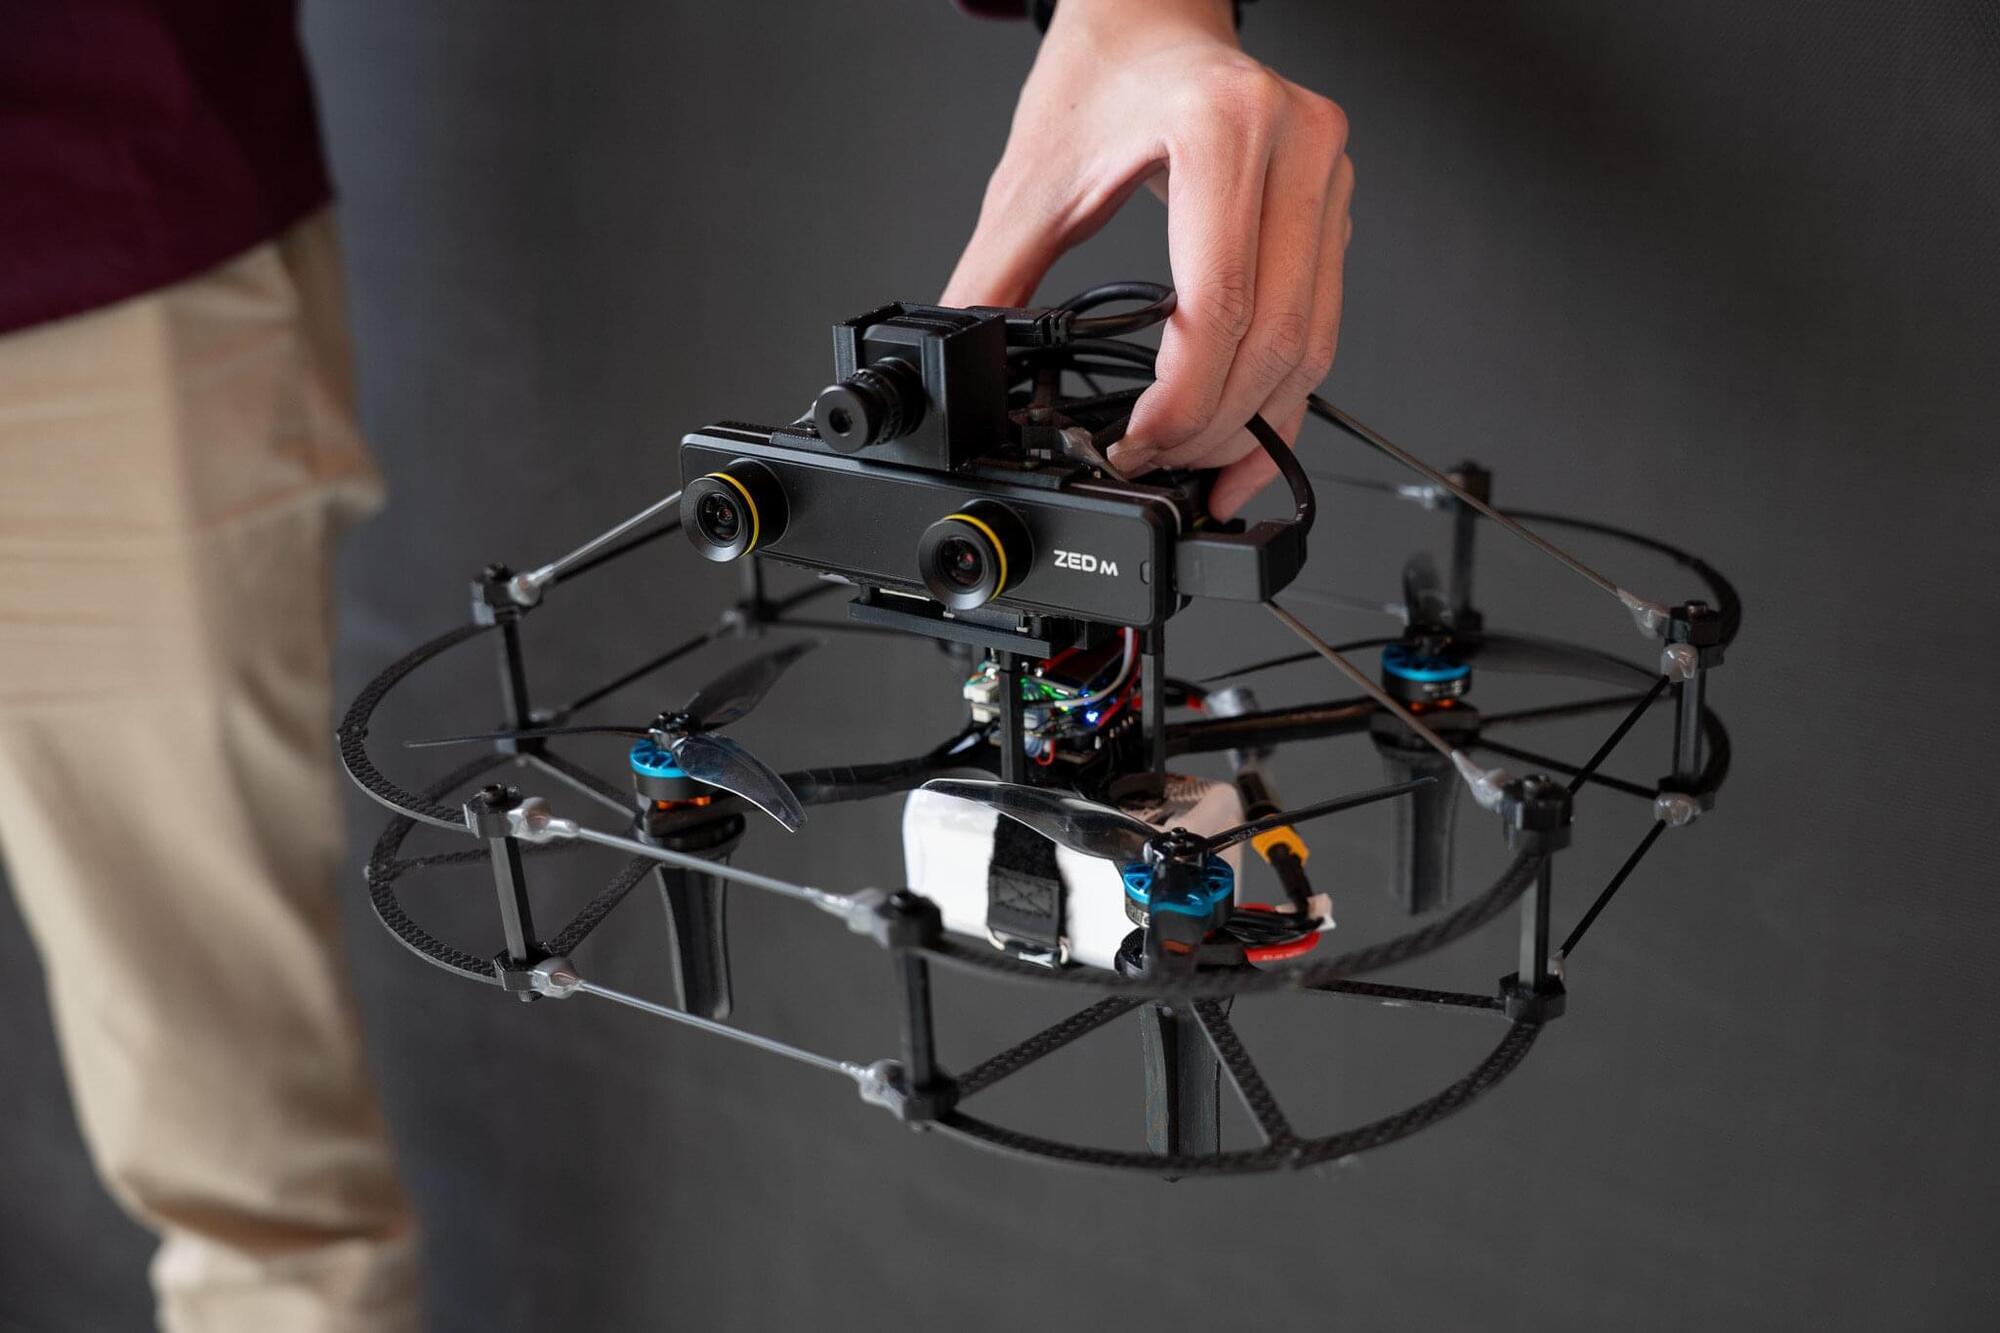
For decades, event cameras, which emulate the biological retina by continuously monitoring changes in light intensity, have promised to revolutionize how robots perceive the world by allowing them to react faster and operate more reliably than conventional cameras permit.
But interpreting event-camera data, which resembles a dizzying stream of points rather than a recognizable series of images, has traditionally required a patchwork of specialized algorithms, each built for a single task.
Now, engineers at the University of Pennsylvania have developed Fast Feature Field, or F³, a general-purpose computational tool to efficiently transform the tens of millions of signals that event cameras produce each second into information that many different kinds of robots can use.