Humans can create loose maps of environments they are exploring in their minds, using their senses and navigation skills. Many robots, on the other hand, rely on set maps of known environments or new maps produced using data collected by their sensors.
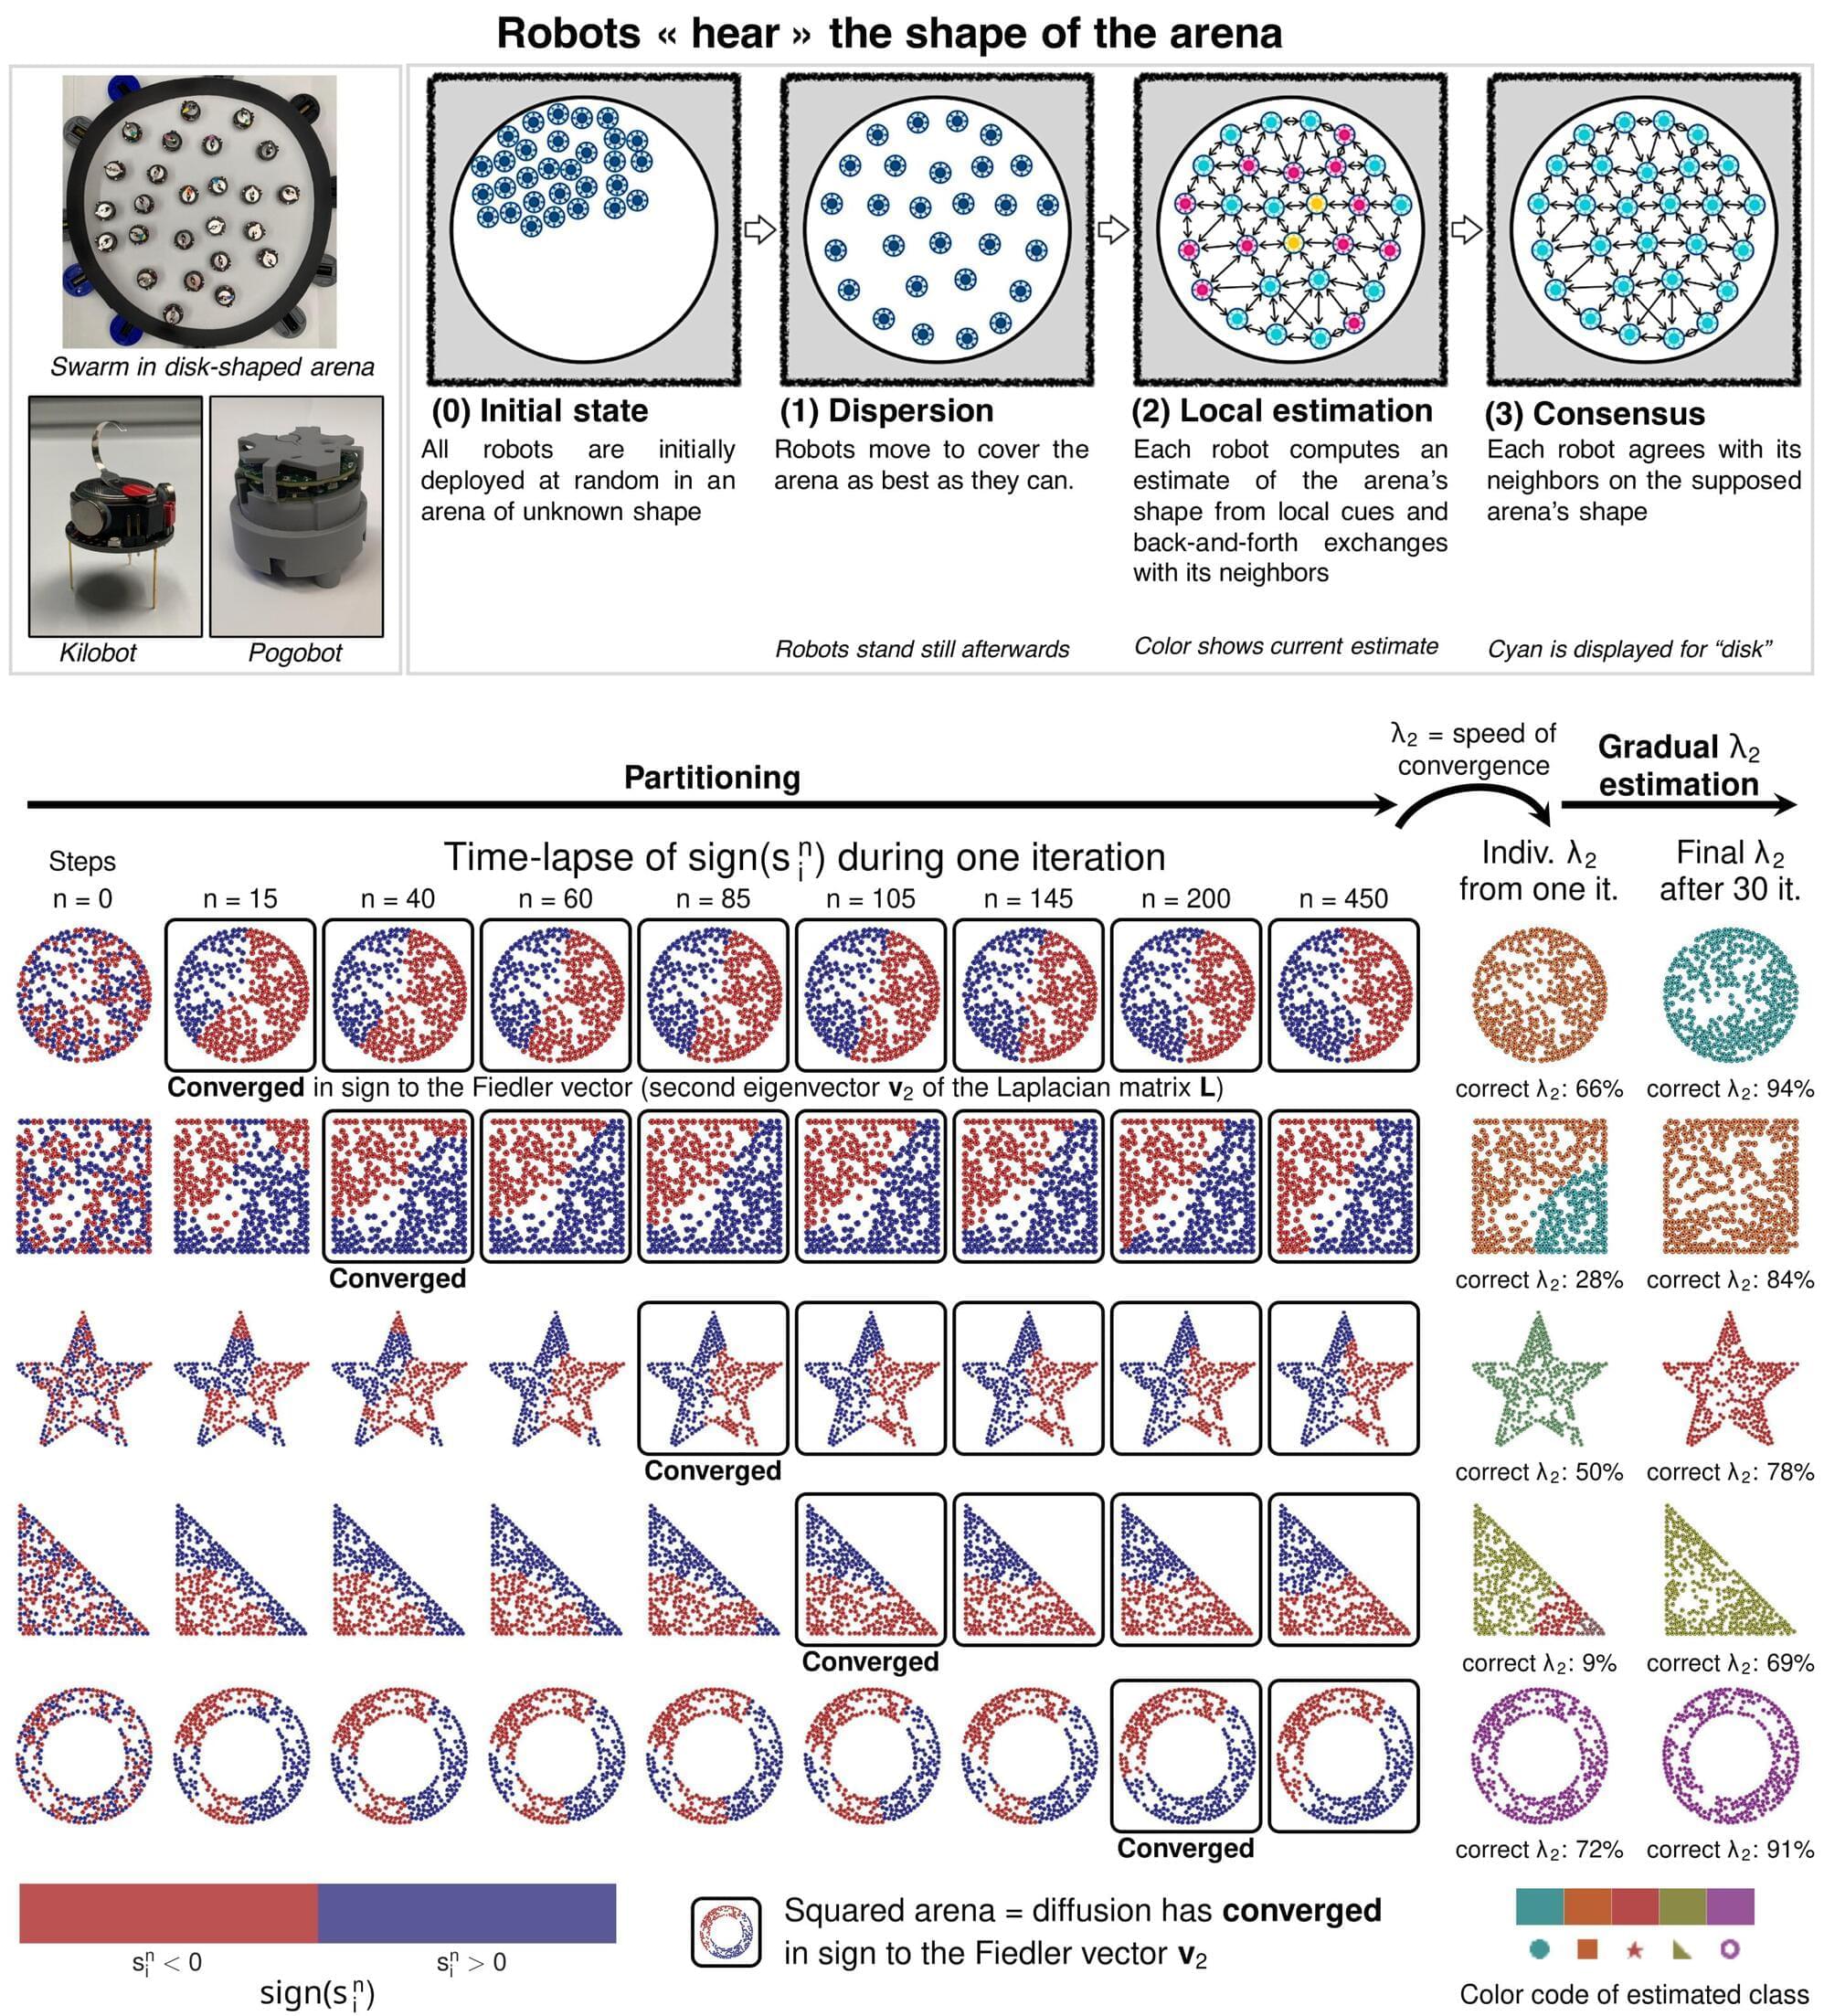
Researchers at Sorbonne University’s Institute of Intelligent Systems and Robotics (ISIR), the University of Tokyo and other institutions recently introduced a framework that could allow a swarm of tiny robots to recognize the shape of an enclosure they are in without a map. Their approach, outlined in a paper published in Science Robotics, allows robots to identify the enclosure from a set of known shapes by repeatedly exchanging messages with nearby robots.
“The project addressed a fundamental question in swarm robotics: how can a group of simple robots perceive something that none of its members can observe alone?” Leo Cazenille, first author of the paper, told Tech Xplore.