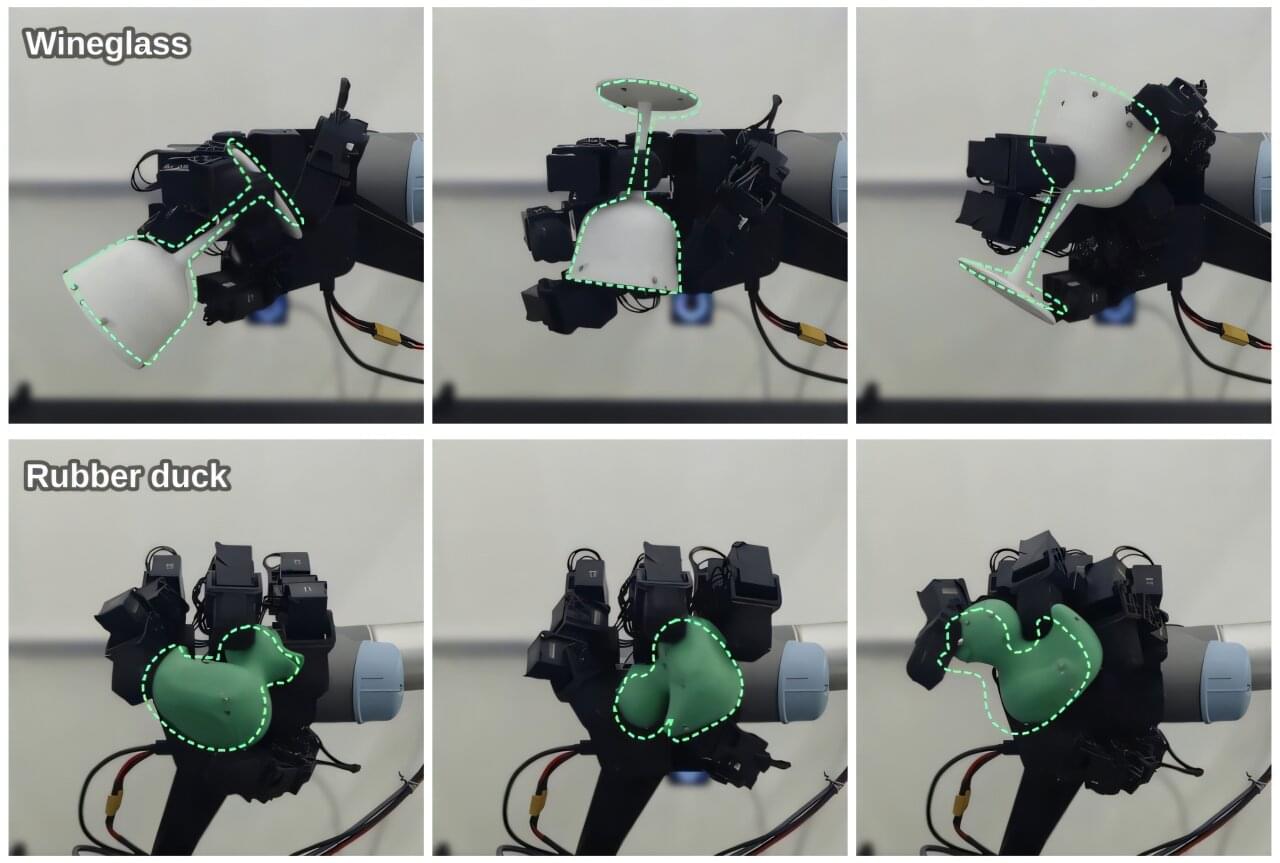
Manipulating an object with one hand is a balancing act. Fingers must release and renew their grip while keeping the object from slipping away, even with the palm facing downward.
Researchers have now trained a robot hand to perform these maneuvers and added a separate software safeguard to reduce object drops. In tests guided by external motion-tracking cameras, the safeguard cut drops from 16 to four over 1,200 requested movement sequences. The trade-off was that the hand missed a few more targeted motions.
Ian Chuang and colleagues at the University of California, Berkeley and Davis describe their work in a paper posted to the arXiv preprint server. Their approach lets researchers adjust how cautiously the hand moves without retraining its underlying skill.