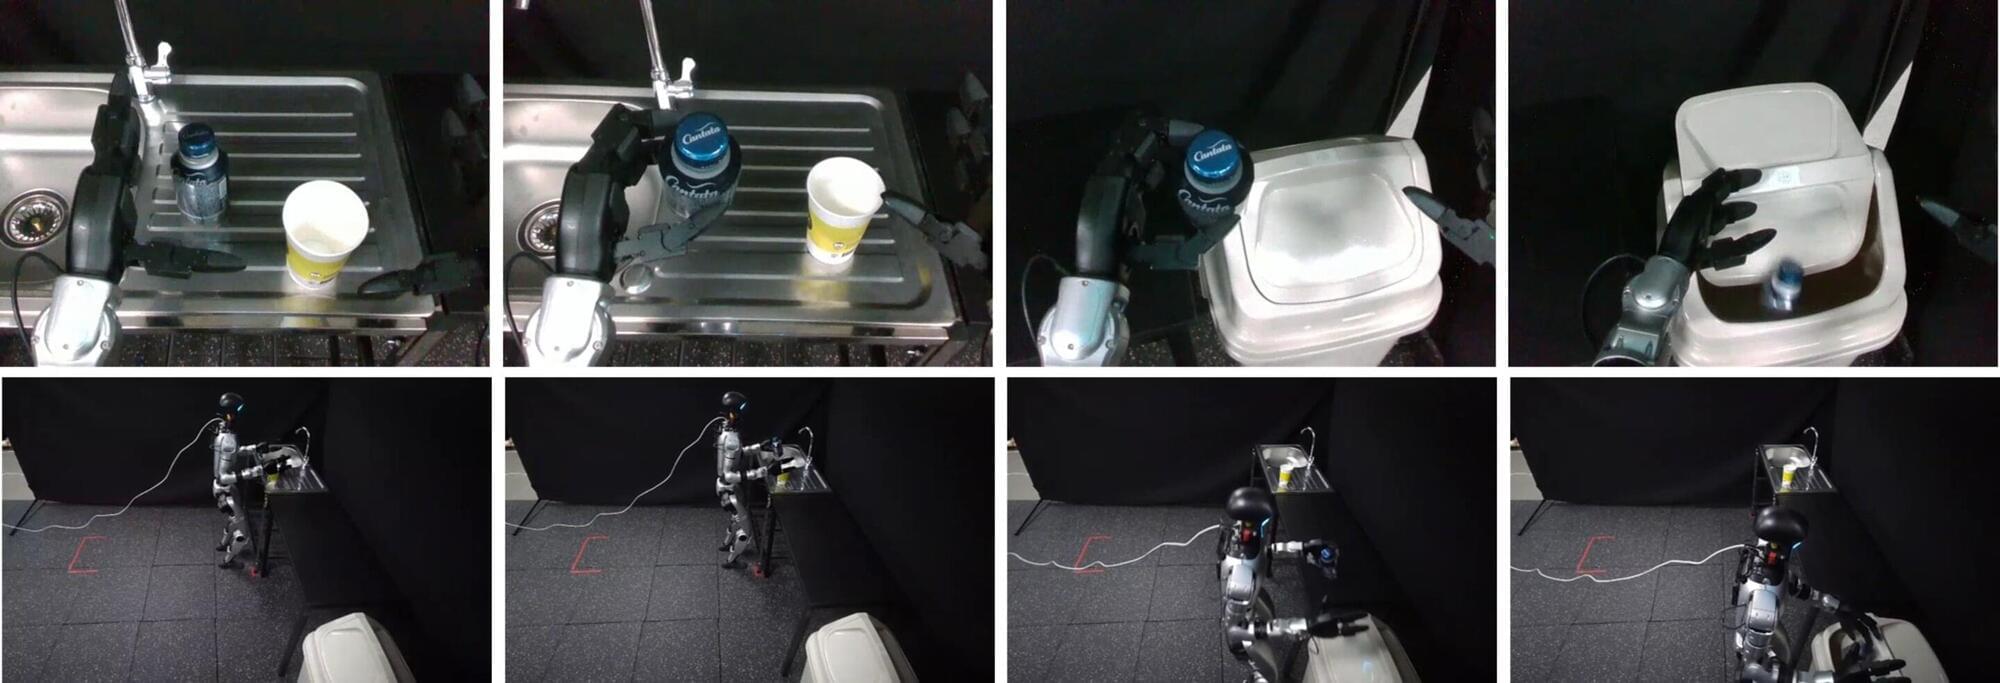
A humanoid AI system has been developed that learns jointly from separately collected locomotion and object-manipulation data to perform multiple stages of a task in sequence.
A research team led by professor Songhwai Oh of the Department of Electrical and Computer Engineering at Seoul National University College of Engineering has developed RISE (Responsibility-Induced Specialized Experts), a vision-language-action (VLA) framework that learns jointly from locomotion and object-manipulation demonstrations collected independently and enables a humanoid robot to perform multistep tasks sequentially.
The team connected locomotion and object manipulation without requiring additional demonstrations of multistep tasks involving transitions between the two behaviors, and validated the framework in both simulation and experiments using a real humanoid robot, the Unitree G1.