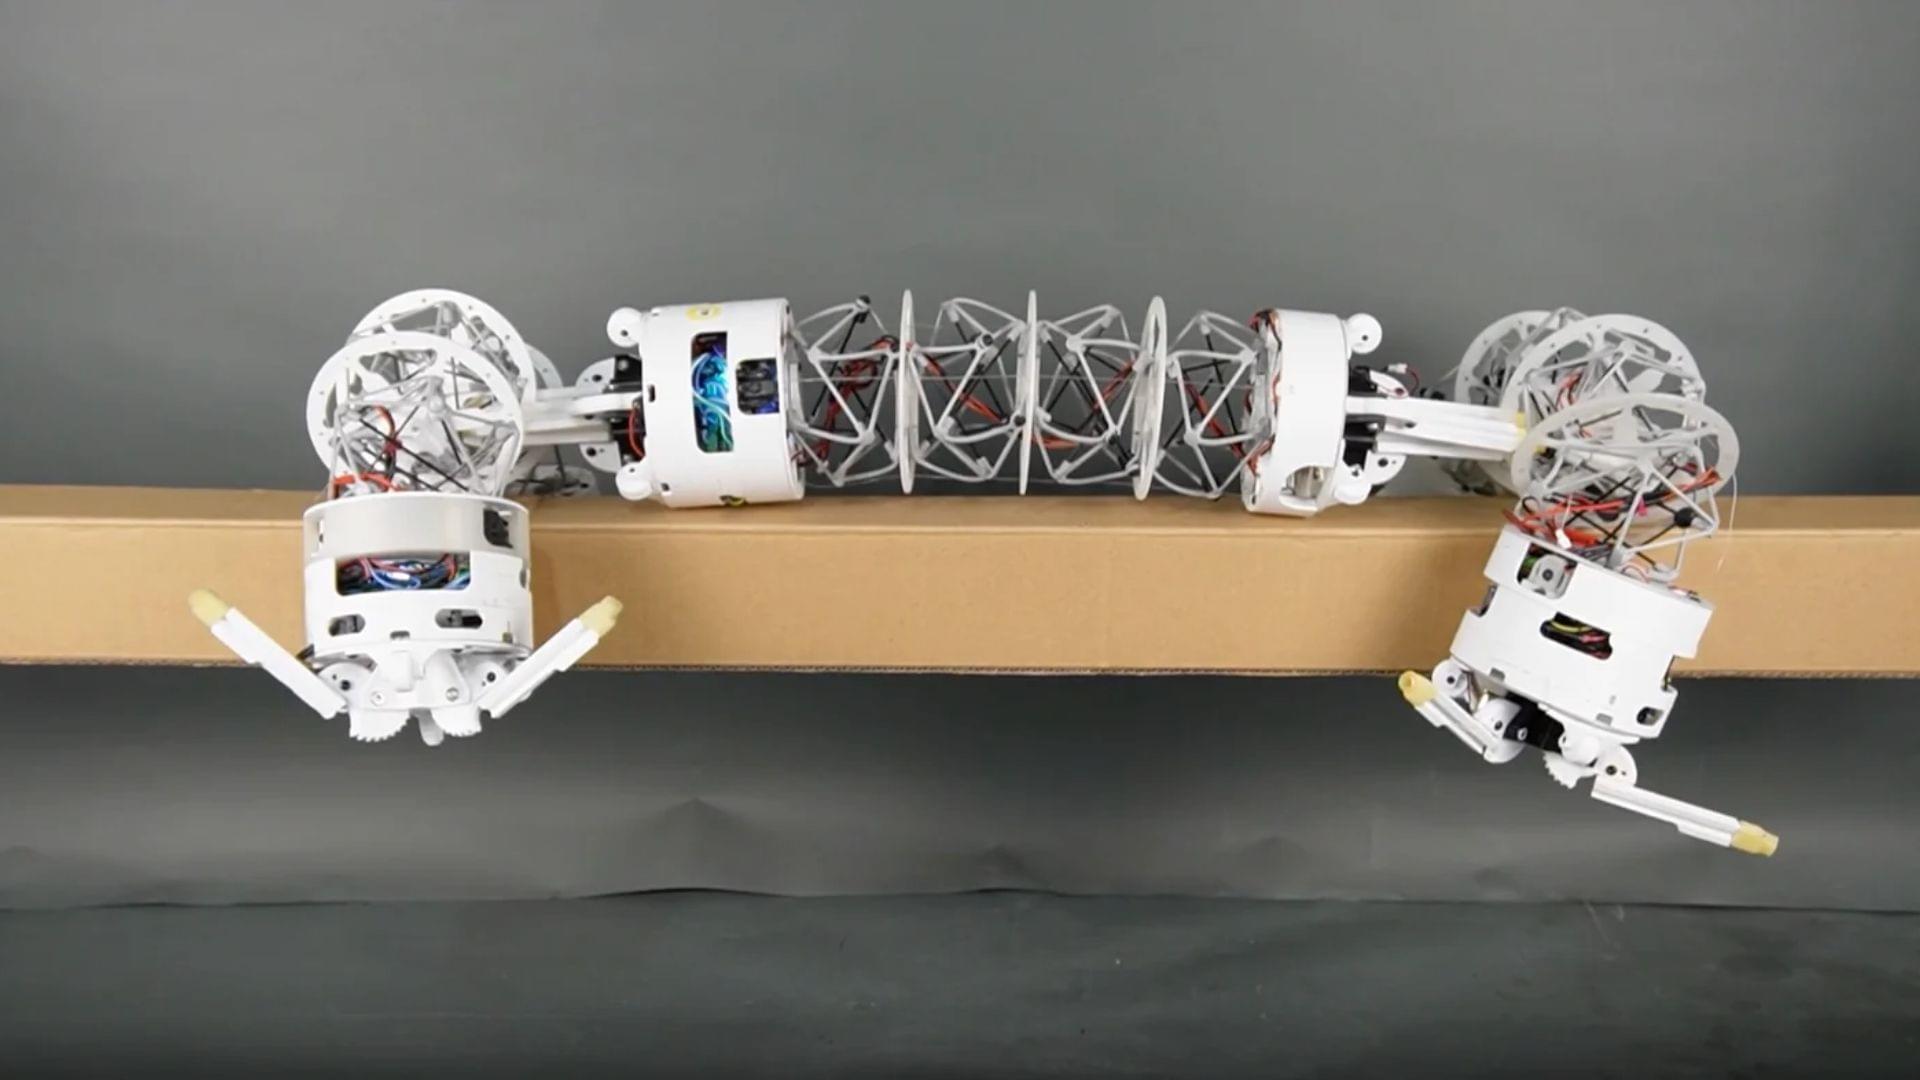
Researchers at Colorado State University have developed flexible robots inspired by elephant trunks that can bend, grip objects, and connect with other machines. The robots use a structural design called tensegrity, in which rigid rods are held together by tensioned cables rather than fixed joints.
The construction allows them to collapse, bend, and change shape while using gripping claws at both ends of their tube-like bodies to manipulate objects or attach to other robots.